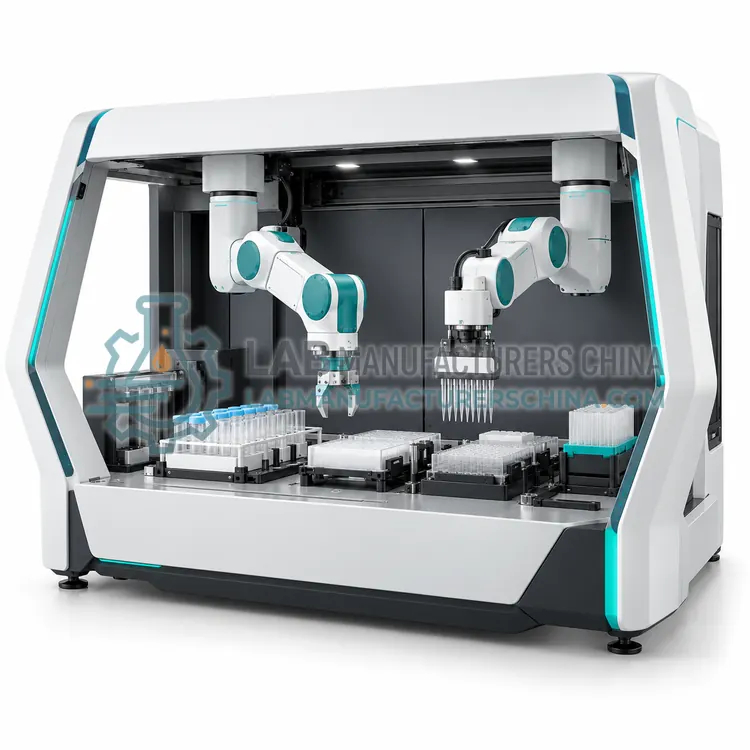
Dual-Arm Robotic System
双臂机器人系统
- SKU LAR-0002
- Laboratory Robotics
- CE (to be confirmed)
- ISO 9001 manufacturing (to be confirmed)
Price on request — FOB / CIF quoted per order
Prices depend on configuration, quantity and destination port.
Key specifications
| Type | Dual-arm robotic system |
|---|---|
| Arms | 2 coordinated |
| Axes per arm | 6–7 |
| Payload per arm | 1–5 kg |
| Repeatability | ± 0.1 mm |
| Safety | Collaborative force and speed |
Request a quote Download brochure · to be provided
By Lab Manufacturers China Technical TeamLast reviewed Standards: IEC 61010-1 (safety requirements for electrical equipment), ISO 10218 (robots and robotic devices, safety requirements), ISO/TS 15066 (collaborative robots)
What is the Dual-Arm Robotic System?
A dual-arm robotic system uses two coordinated arms to handle tasks needing two hands, such as opening containers and holding labware. It suits complex manipulation in automated workflows with force-limited collaborative safety.
What is the Dual-Arm Robotic System?
A dual-arm robotic system uses two coordinated arms to handle tasks needing two hands, such as opening containers and holding labware. It suits complex manipulation in automated workflows with force-limited collaborative safety.
Overview
Two arms on a common base work together under one controller, so one can hold a vessel while the other uncaps, pipettes or retrieves an item. Each arm typically has 6 or 7 axes with payload of 1–5 kg each and repeatability of ± 0.1 mm, and the arms can be fitted with different grippers for complementary tasks. Coordinated control allows collision avoidance between the arms and precise relative positioning. Safety usually relies on force and speed limits for collaborative operation, since the arms share space with operators. The system suits handling that is difficult for a single arm, such as screw-cap tubes, flexible tubing, septum vials and instruments that require two simultaneous actions, and it is often used in complex sample preparation and long unattended protocols.
How does it work?
A laboratory robot produces precise, repeatable movement so that labware reaches the right place at the right time. A robot arm has joints driven by servomotors, with position feedback from encoders and a gripper that opens to the width of a plate, tube or rack. The controller executes a taught or programmed path with repeatability often better than ± 0.1 mm, and safety systems limit force or stop motion if a person enters the workspace. Mobile robots navigate on a map using laser or camera sensors and carry racks between benches. Storage robots move trays between shelves and a transfer station, retrieving a requested sample by barcode. Plate handlers move microplates between readers, washers and incubators. All are coordinated by scheduling software that knows labware positions, instrument states and the method, so a workflow runs without manual transfers.
What are the key features?
- Two coordinated arms on one controller
- 6–7 axes per arm
- Payload 1–5 kg per arm
- Repeatability about ± 0.1 mm
- Collaborative force and speed limits
- Different grippers per arm
What are the technical specifications?
A typical dual-arm robotic system configuration offers type of Dual-arm robotic system, arms of 2 coordinated, axes per arm of 6–7, payload per arm of 1–5 kg, repeatability of ± 0.1 mm and safety of Collaborative force and speed. Values are indicative of the product class; the exact figures for each configuration are confirmed on the quotation and the calibration documents supplied with the instrument.
Which applications is it used for?
The Dual-Arm Robotic System is used in screw-cap tube handling, septum vial preparation, complex sample preparation and flexible item manipulation. Across the wider Laboratory Robotics class, laboratories also deploy it for linked analytical workflows, sample and compound storage and plate-based screening.
Which standards and certifications apply?
Relevant standards and methods include IEC 61010-1 (safety requirements for electrical equipment), ISO 10218 (robots and robotic devices, safety requirements), ISO/TS 15066 (collaborative robots), ANSI/SLAS microplate standards, 21 CFR Part 11 (electronic records and signatures) and USP <1058> (analytical instrument qualification). Certification candidates for this model are CE and ISO 9001 manufacturing; each is to be confirmed for the specific configuration before shipment, and certificates are supplied only where they have been issued.
Assess risks before installation and apply guarding, light curtains, force limits or collaborative safety functions as required by ISO 10218 and ISO/TS 15066 where applicable. Verify repeatability, payload and gripper alignment on installation and after any collision or service, since small offsets cause missed picks and dropped plates. Keep fixtures, plates and racks within specification, because worn or warped labware defeats a precise gripper. Define and test error recovery so the robot can pause, report and resume rather than lose a run. Maintain a spare-parts and service plan, and train operators to clear jams safely and to know when to call service. Record all changes to taught positions and software, and revalidate after major modifications.
How do I select the right Dual-Arm Robotic System?
Choose dual arms when tasks genuinely need two hands, such as uncapping while holding. Confirm coordination, safety and gripper options. RFQ: task list, object types, payload, throughput and safety approach. Provide the task list and object types.
How does it compare with other Laboratory Robotics variants?
Choose the lowest level of robotics that solves the problem. A single arm workstation suits a defined set of steps at one bench, while dual-arm systems handle more complex manipulation, such as handling flexible items. A mobile robot is useful where samples must move between existing instruments that cannot be reconfigured, and a storage robot suits large sample or compound libraries needing fast retrieval. Plate handlers integrate microplate instruments cheaply but handle only plates. Confirm reach, payload, gripper designs and the labware you use, since gripping and positioning are the usual failure points. Check the safety approach, including force limits, guarding or light curtains, and confirm the scheduling software supports your workflows, error recovery and LIMS exchange. Consider service, spare parts and training, because a central robot failure stops everything it feeds.
Full specifications
| Type | Dual-arm robotic system |
|---|---|
| Arms | 2 coordinated |
| Axes per arm | 6–7 |
| Payload per arm | 1–5 kg |
| Repeatability | ± 0.1 mm |
| Safety | Collaborative force and speed |
| Grippers | Independent per arm |
| Coordination | Collision avoidance |
| Control | Single controller |
| Dexterity | Two-handed tasks |
Indicative values for this product class. Final specifications are confirmed on the quotation and in the calibration documents supplied with the instrument.
Applications
- Screw-cap tube handling
- Septum vial preparation
- Complex sample preparation
- Flexible item manipulation
Key features
- Two coordinated arms on one controller
- 6–7 axes per arm
- Payload 1–5 kg per arm
- Repeatability about ± 0.1 mm
- Collaborative force and speed limits
- Different grippers per arm
Frequently asked questions about Dual-Arm Robotic System
When a task requires holding one part while acting on another, such as uncapping a tube, connecting tubing or presenting a vial to a septum. If each step is sequential, one arm is usually enough.
By collaborative safety functions that limit force and speed, detect contact and stop quickly, following ISO/TS 15066. A risk assessment determines whether the arms may share space with people.
Not necessarily. It is common to fit a holding gripper on one arm and a precision or tool gripper on the other, so the pair can perform complementary actions on the same object.
Often better than ± 0.1 mm for placing plates and tubes accurately, though the useful figure depends on gripper design and labware tolerance. Repeatability should be verified with the actual labware.
ISO 10218 and, for collaborative operation, ISO/TS 15066 cover risk assessment, guarding, force and speed limits and emergency stop. The specific measures depend on whether people work inside the robot's workspace.
Different plates, tubes and racks vary in size and stiffness, so a gripper set for one labware may misplace another. Gripper designs and taught positions must be matched to each labware and verified.
Related models